Connect Four Robot: Reinforcement Learning on Embedded Hardware

The Connect Four robot is a physical demonstrator for reinforcement learning. It was originally developed as a master’s project in the EIM program (Electrical Engineering and Information Technology) by the students Alexander Bernhardt, Christian Bernhardt, Raphael Carli and Manuel Reichelt.
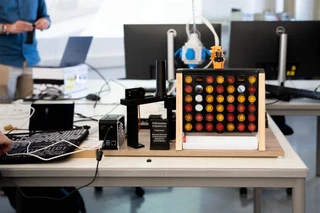
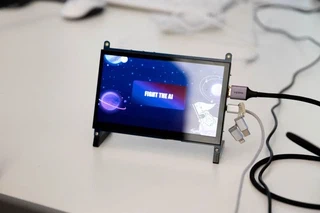
In addition to a DQN agent, a Monte Carlo Tree Search (MCTS) agent and AlphaZero were implemented. All algorithms were parameterized to run in real time on a Raspberry Pi 4. Different difficulty levels can be selected via a touch display. At the highest level, winning against the AI is nearly impossible.
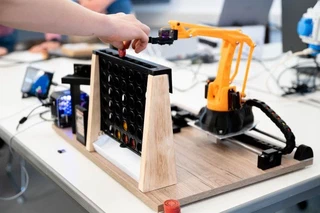
Alongside the software, an open-source robot arm was built with a 3D printer, a sensor system was set up on a real game board, and a magazine was designed from which the robot arm picks up the game pieces.
The robot attracted the interest of local media, who visited the project at HTWG in autumn 2023. A Regio TV report about the project is available in the media library: https://www.regio-tv.de/mediathek/video/regio-tv-bodensee-journal-17-10-2023/ (in German)
An article was also published in the Südkurier: https://www.suedkurier.de/region/kreis-konstanz/konstanz/dieser-vier-gewinnt-roboter-verliert-nie-htwg-studierende-stellen-master-projekt-vor;art372448,11758007 (in German)
Current work
The setup is currently being extended with a Dobot Magician E6, a six-axis collaborative robot arm.
